Reachable Sets for Safe, Real-Time Manipulator Trajectory Design
Patrick Holmes · Shreyas Kousik · Bohao Zhang · Daphna Raz · Corina Barbalata · Matthew Johnson-Roberson · Ram Vasudevan
TL;DR
ARMTD plans robot arm trajectories in real time using precomputed reachable sets and a braking fail-safe, avoiding collisions in simulation and hardware tests.
BRIEF
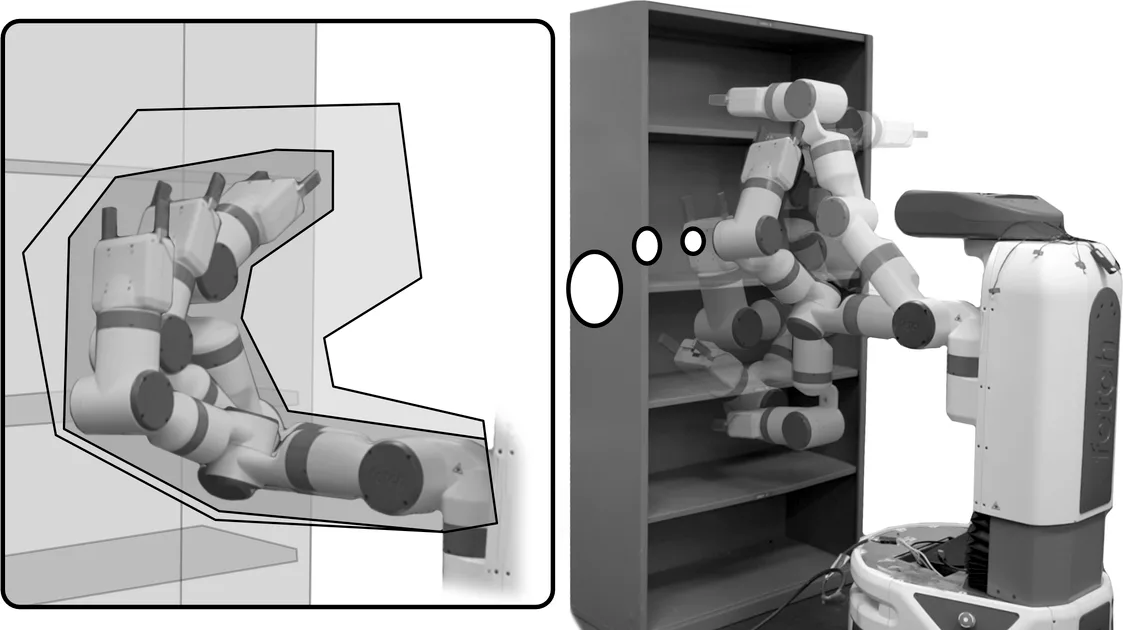
Robot arms working near people need motion plans that are provably safe, but careful planning is usually slow and fast planning is often unsafe. ARMTD resolves this by precomputing, offline, the space swept by a family of parameterized joint trajectories, each ending in a braking maneuver. At runtime it intersects the arm's reachable set with obstacles to build conservative collision constraints, then optimizes over trajectory parameters. On a 6-degree-of-freedom arm, it outperformed CHOMP in simulation and completed real-time hardware tasks without collisions.
Abstract
For robotic arms to operate in arbitrary environments, especially near people, it is critical to certify the safety of their motion planning algorithms. However, there is often a trade-off between safety and real-time performance; one can either carefully design safe plans, or rapidly generate potentially-unsafe plans. This work presents a receding-horizon, real-time trajectory planner with safety guarantees, called ARMTD (Autonomous Reachability-based Manipulator Trajectory Design). The method first computes (offline) a reachable set of parameterized trajectories for each joint of an arm. Each trajectory includes a fail-safe maneuver (braking to a stop). At runtime, in each receding-horizon planning iteration, ARMTD constructs a reachable set of the entire arm in workspace and intersects it with obstacles to generate sub-differentiable and provably-conservative collision-avoidance constraints on the trajectory parameters. ARMTD then performs trajectory optimization for an arbitrary cost function on the parameters, subject to these constraints. On a 6 degree-of-freedom arm, ARMTD outperforms CHOMP in simulation and completes a variety of real-time planning tasks on hardware, all without collisions.