Hybrid Visual SLAM for Underwater Vehicle Manipulator Systems
Gideon Billings · Richard Camilli · Matthew Johnson-Roberson
TL;DR
A visual SLAM system combines a vehicle stereo camera with a wrist-mounted fisheye camera to map natural seafloors for underwater manipulators.
BRIEF
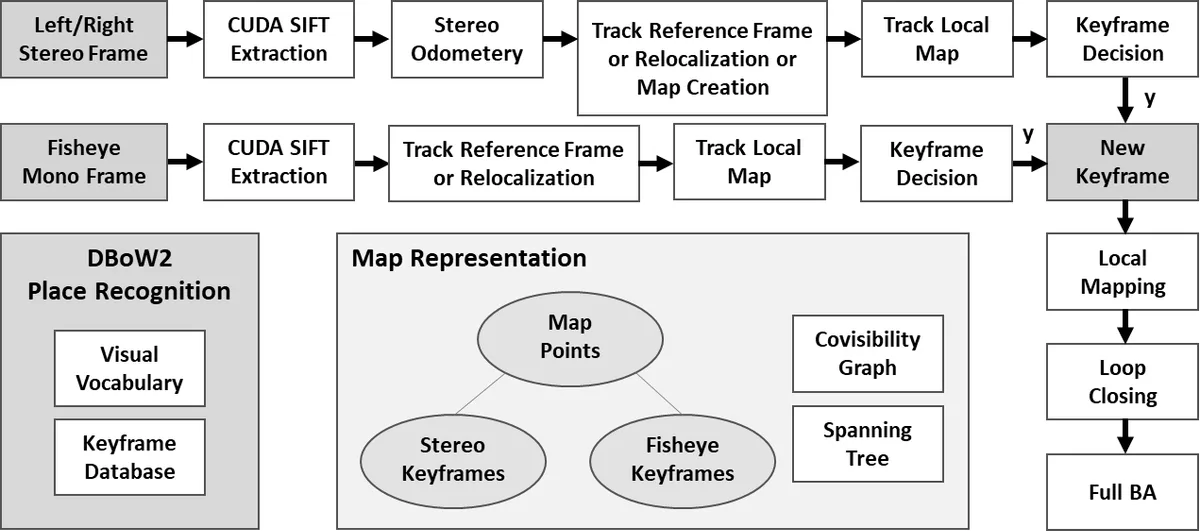
Underwater vehicles fitted with robotic arms need accurate maps of the seafloor to work near it, but natural terrain offers few clean landmarks and the vehicle's cameras see only a limited view. This work builds a feature-based map using GPU-accelerated SIFT features and graph optimization. A stereo camera on the vehicle fixes the map's scale, while a fisheye camera on the arm's wrist adds features that extend the map beyond the vehicle's view. Tests on deep-sea and reef datasets show accurate mapping, and the datasets are released publicly.
Abstract
This letter presents a novel visual feature based scene mapping method for underwater vehicle manipulator systems (UVMSs), with specific emphasis on robust mapping in natural seafloor environments. Our method uses GPU accelerated SIFT features in a graph optimization framework to build a feature map. The map scale is constrained by features from a vehicle mounted stereo camera, and we exploit the dynamic positioning capability of the manipulator system by fusing features from a wrist mounted fisheye camera into the map to extend it beyond the limited viewpoint of the vehicle mounted cameras. Our hybrid SLAM method is evaluated on challenging image sequences collected with a UVMS in natural deep seafloor environments of the Costa Rican continental shelf margin, and we also evaluate the stereo only mode on a shallow reef survey dataset. Results on these datasets demonstrate the high accuracy of our system and suitability for operating in diverse and natural seafloor environments. We also contribute these datasets$^{3}$ for public use.