Real-Time Model Predictive Control for Energy Management in Autonomous Underwater Vehicle
Niankai Yang · Mohammad Reza Amini · Matthew Johnson-Roberson · Jing Sun
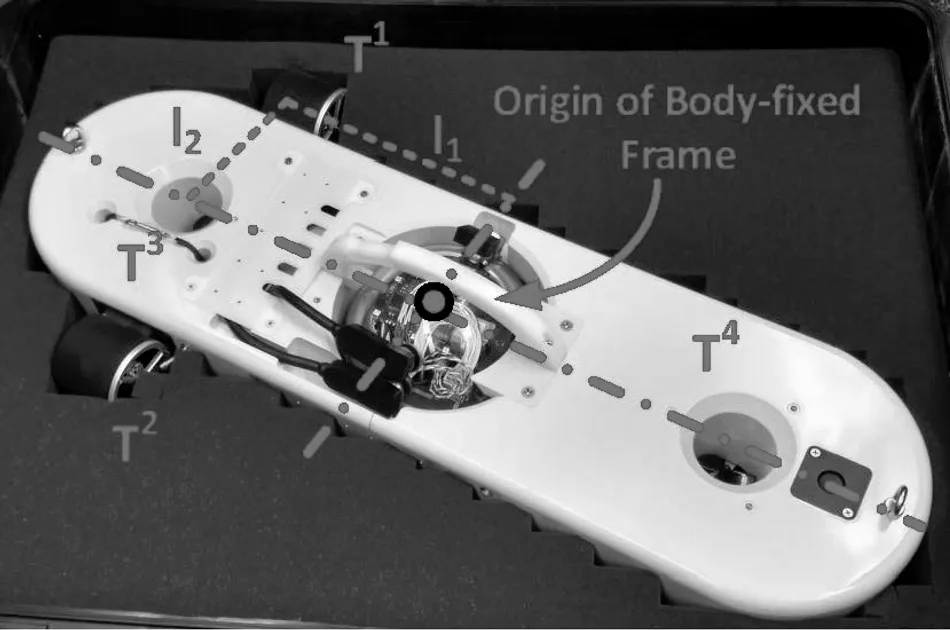
TL;DR
A two-stage model predictive controller with switching logic gets near-optimal energy use for point-to-point AUV travel in simulation, at much lower computational cost.
BRIEF
Autonomous underwater vehicles can only travel as far as their batteries allow, so using energy wisely extends how much of the ocean they can cover. This work treats point-to-point travel as an energy optimization problem. A static step first balances the cost of fighting the vehicle's positive buoyancy against the cost of overcoming drag while moving forward. A model predictive controller then handles transients and vehicle dynamics, with switching logic between the two stages to cut computation. In simulation, it achieved near-optimal energy use at much lower computational cost.
Abstract
Improving endurance is crucial for extending the spatial and temporal operation range of autonomous underwater vehicles (AUVs). Considering the hardware constraints and the performance requirements, an intelligent energy management system is required to extend the operation range of AUVs. This paper presents a novel model predictive control (MPC) framework for energy-optimal point-to-point motion control of an AUV. In this scheme, the energy management problem of an AUV is reformulated as a surge motion optimization problem in two stages. First, a system-level energy minimization problem is solved by managing the trade-off between the energies required for overcoming the positive buoyancy and surge drag force in static optimization. Next, an MPC with a special cost function formulation is proposed to deal with transients and system dynamics. A switching logic for handling the transition between the static and dynamic stages is incorporated to reduce the computational efforts. Simulation results show that the proposed method is able to achieve near-optimal energy consumption with considerable lower computational complexity.